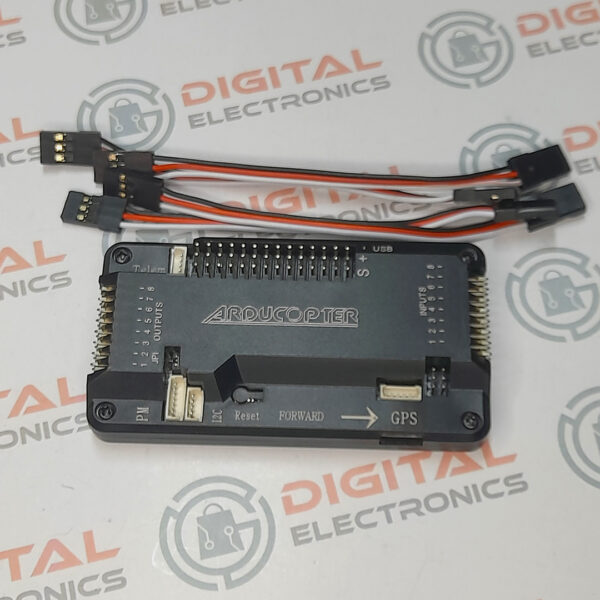
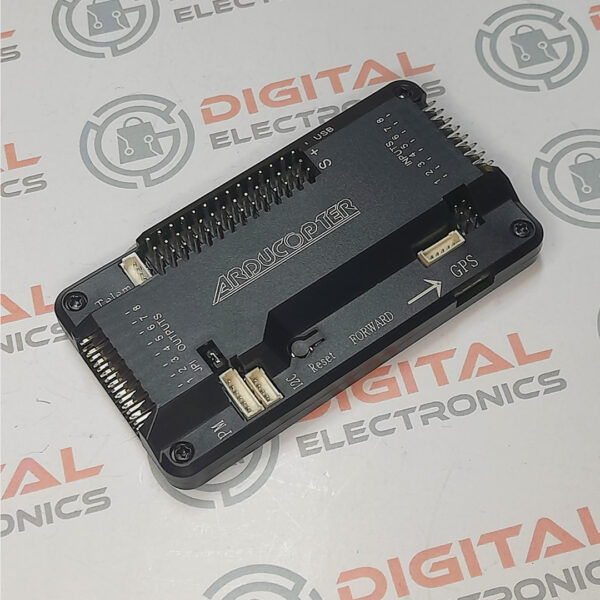
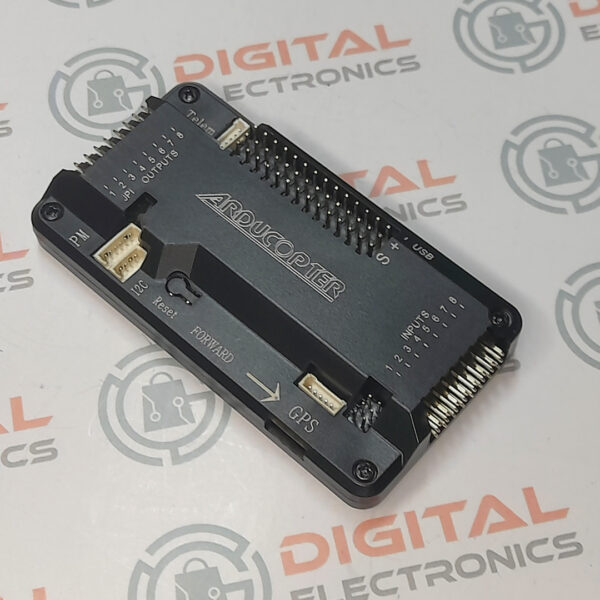
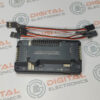
APM 2.8 Flight Control Board
Br15,000.00
- Microcontroller: ATmega2560 and ATMEGA32U-2
- IMU (Inertial Measurement Unit): Invensense MPU-6000 (6 DoF: 3-axis gyro + 3-axis accelerometer)
- Barometric Pressure Sensor: MS5611-01BA03
- Compass (Magnetometer): Built-in, with an option for an external module via a jumper
- Dataflash: 4MB onboard chip for automatic data logging
- GPS Compatibility: Requires an optional off-board GPS module (e.g., uBlox LEA-6H) for full autonomy
- Power Supply: Uses a regulator that can accept a 16V max input, though some kits may have a power module with a 30V max input.
- Connectivity: MUX (for UART0, UART2, I2C), includes a jumper for selecting built-in or external compass
- Features: Open-source, Arduino-compatible, supports various flight modes, and can be used for multirotors, rovers, and boats
Related products
-
NodeMCU ESP8266
Br1,450.00 -
F450 Propeller Blade
Br2,000.00 -
SD Card Module
Br600.00 -
Arduino Pro Mini
Br1,150.00